kalbee
kalbee is a clean, modular Python toolkit for filtering and tracking. It provides a unified interface for 18 filter types, smoothers, multi-object trackers, diagnostic metrics, and a built-in experiment runner to compare filter performance.
Highlights
| Category | What you get |
|---|---|
| 18 Filters | KF, EKF, UKF, SigmaPointUKF, CKF, PF, RBPF, EnKF, Information, ABG, Adaptive, Square-Root/Cholesky, Vectorized, Fading-Memory, H∞, IMM, VB, InEKF |
| Sigma Points | Simplex, MerweScaled, Julier — pluggable via Strategy pattern |
| Motion Models | Ready-made constant-velocity, constant-acceleration, and coordinated-turn \((F, Q)\) builders |
| Tracking | SORT-style multi-object tracker with Hungarian association and gating |
| Learning | Offline EM to fit \(Q\)/\(R\) from data, plus NIS-based auto-tuning |
| Smoother | Rauch-Tung-Striebel (RTS) backward smoother |
| Diagnostics | RMSE, NEES, NIS, Log-Likelihood, FilterDiagnostics, consistency tests |
| Outlier Rejection | Chi-squared gating, Mahalanobis gating, adaptive outlier detection |
| Experiments | One-liner to compare filters on synthetic signals |
| Stability | Joseph form covariance updates, Cholesky factor stabilization, symmetry checks |
| Utilities | Batch processing, state serialization, control inputs, missing data handling |
See It In Action
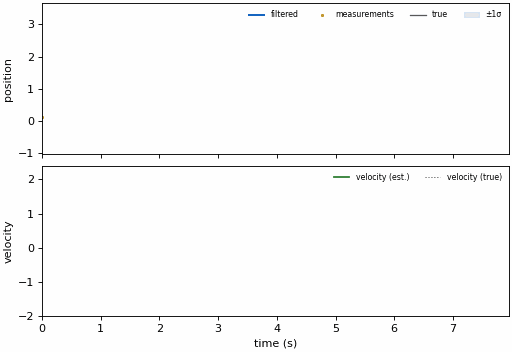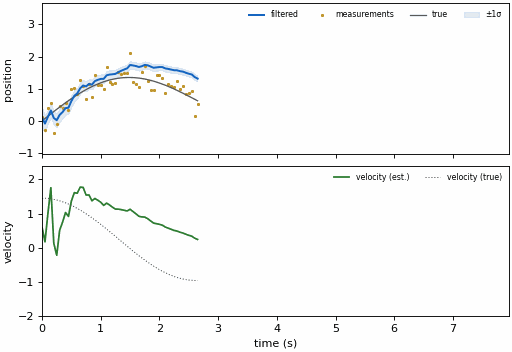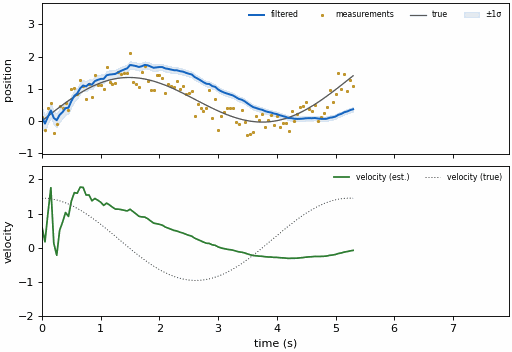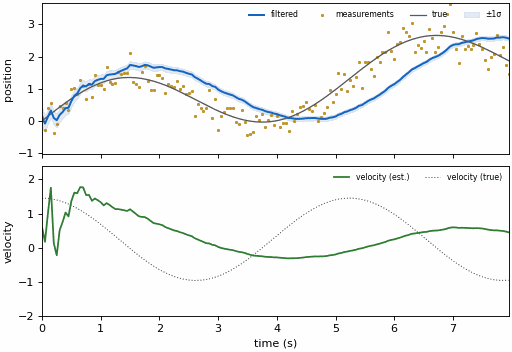
Animated demos for filtering, maneuvering targets (IMM) and real-pedestrian multi-object tracking live in the Examples & Gallery.
Quick Start
from kalbee import run_experiment

# Compare filters on a sine wave
report = run_experiment(
    signal="sine",
    filters=["kf", "ekf", "ukf", "pf"],
    noise_std=0.5,
)
print(report.summary())
Navigation
- Getting Started — Installation, core concepts, first filter
- Examples & Gallery — Animated demos and copy-paste recipes
- Filters — Deep dive into each filter with theory + code
- Features — Motion models, tracking, learning, diagnostics
- Architecture — Design philosophy and extensibility